Geared Induction Motors Closed Loop Commissioning
The Elevator Core drive can control Geared Induction Motors in Closed Loop (with Encoder Feedback).
Below are the steps for commissioning the drive for a Geared Closed Loop application:
For this guide it is assumed that the electrical wiring follows the default wiring example from below.

For full detail on electrical installation see the topic electrical installation.
Below are all the checks that must be preformed before applying any power to the drive.
Action/Checks | |
|---|---|
 Do Not Apply Electrical Power Yet! |
|
Check all necessary electrical connections |
|
Check all necessary electrical connections to the Encoder Module |
|
Action/Checks | |
|---|---|
 Apply Electrical Power to the drive |
|
 Check Encoder Module |
|
Step 4 is entering the values from the motor nameplate into the parameters in Group 4.
Warning
This step is mandatory and each parameter needs to have the correct value. If these parameters are not entered or incorrect then the motor could be damaged.
Action | Parameter Change | Additional Information |
|---|---|---|
Select Geared (Induction) motor control |
| Some older motors may work better in simple vector mode. To do this set P4-01 to 1 |
Enter motor rated voltage (P4-02) |
| Enter Voltage value as shown on the motor nameplate (Volts). |
Enter Motor Rated Current (P4-03) |
| Enter Current value as shown on the motor nameplate (Amps). |
Enter Motor Rated Frequency (P4-04) |
| Enter Frequency value as shown on the motor nameplate (Hz). |
Enter Number of Motor Poles (P4-05) |
| Enter motor pole value as shown on the motor nameplate, if unknown set P4-05 to 0 where the drive will automatically calculate the value providing P4-04 (Motor Rated Frequency) and P4-06 (Motor Rated Speed) have been entered correctly. |
Enter Motor Rated Speed (P4-06) |
| Enter motor rated speed value as shown on the motor nameplate (rpm). The drive display will now show motor speed in estimated rpm. All speed related parameters, such as Minimum and Maximum Speed, High Speeds etc. will also be displayed in rpm. This parameter must be entered to set 0 in Parameter P4-05 to auto calculate the number of motor poles. If you want the drive to display the speed in Hz leave this parameter at 0. |
Enter Motor power factor Cos Ø (P4-07) |
| Obtained from Motor nameplate. If Motor power factor is unknown leave as default value and set P4-01 to 1. The drive can auto calculate this value. When the motor is running, parameter P0-22 displays the measured power factor value, and this can then be entered into P4-07. The closer you run to rated speed and load the more accurate this measurement. |
Enter the Maximum speed (P8-01) |
| This is the maximum allowable speed. |
During this step we will set up the encoder. This step assumes that the Universal Encoder Module is connected to the drive and correctly wired up. For full details on the mechanical or electrical installation of the Universal Encoder Module refer to the topic - Universal Encoder Module Installation.
For details on the encoder connections see the section Universal Encoder Module - Encoder Connections in this topic.
Action/Check | Parameter Change | Additional Information | |
|---|---|---|---|
Enter Encoder Resolution |
| Refer to the Encoder datasheet or Encoder nameplate | |
Select Encoder Type |
| P6-04 Setting | Encoder Type |
0 (Default) | No Encoder Type Selected | ||
1 | Incremental TTL- Differential (A,/A,B,/B) (RS422) | ||
2 | Incremental HTL-Differential (A,/A,B,/B) (24V) | ||
5 | Incremental TTL- Differential (A,/A,B,/B, Z,/Z) (RS422) | ||
6 | Incremental TTL (A,B) | ||
7 | Incremental TTL (A,B, Z) | ||
8 | Incremental HTL- Differential (A,/A,B,/B, Z/Z) (24V) | ||
9 | Incremental HTL (A,B) (24V) | ||
10 | Incremental HTL (A,B,Z) (24V) | ||
Note
Regardless of the encoder type selected the encoder shield must always be connected to the Universal Encoder Module. Failure to do so could result in dropped messages between the encoder and drive causing instability in the motor.
For details on the connection quality between the encoder and the Universal Encoder Module refer to the parameter P6-14 Encoder comms quality.
Below is the connection table for the Universal Encoder Module.
Encoder Type | 24V | 0V | 5V/8V | A+/Sin+ | A-/Sin- | B+/Cos+ | B-/Cos- | C+/CLK+ | C-/CLOCK | D+/DATA+ | D-/DATA | Shield |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
Incremental TTL Differential | 0V | 5V | A+ | A- | B+ | B- | Cable Shield | |||||
Incremental HTL Differential | 24V | 0V | A+ | A- | B+ | B- | ||||||
Incremental TTL | 0V | 5V | A | Connect to 0V | B | Connect to 0V | ||||||
Incremental HTL | 24V | 0V | A | Connect to 0V | B | Connect to 0V |
A Motor Auto-tune must be carried out in order to measure the motor electrical characteristics, brakes will be applied by the drive (unless controlled by other means) during this test.
Action/Check | Additional Information | ||
|---|---|---|---|
System Check |
NoteFor the motor contactor to close the safety chain will need to be closed. Unless using Macro 9 or Macro 11. | ||
Safety Chain Check |
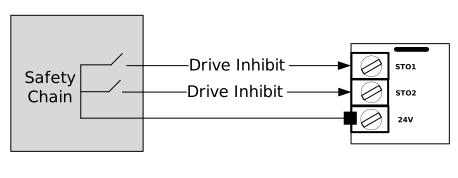 | To start the Auto-tune the Safety Chain inputs must be closed (STO1 & STO2). You are able to pre-load the Auto-tune in P4-08 while the drive shows inhibit (Safety Chain open), so as soon as the Safety Chain close. NoteThe STO input status can be viewed in parameter P0-03 (0 = Open 1 = Closed). | |
Enable Auto-tune |
| Auto-tune Sequence
NoteIf the drive trips refer to the Troubleshooting topic. | |
Note
The Motor Auto-tune will need to be repeated if the motor, motor cables, motor parameters or drive control mode is changed in P4-01.
This step details the procedure to run the elevator car for the first time.
Action/Check | Guidance | |
|---|---|---|
| Ideally the Lift car should be balanced (i.e. with brakes off, the lift car should not naturally move) and with enough shaft headroom to prevent reaching end stops during initial test travels. | |
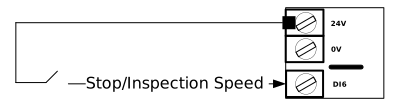
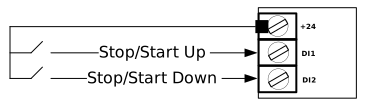
| Steps to run the elevator at a reduced speed
NoteIf the drive trips refer to the Troubleshooting topic. | |
| Steps to check the run direction
| |
| Once all of the above Actions have been completed you can enable the Encoder to run in Closed Loop. To enable the Encoder set P6-05 to 1. | |
| ||
| ||